Skip to content
Projects
Autonomous Surgical Robotics
- Task planning and VLA-based skill execution for autonomous laparoscopic manipulation.
- Task-network planning for multi-arm coordination and skill switching.
- World-model-assisted data augmentation for VLA skills.
- Constraint monitoring and online recovery during execution.
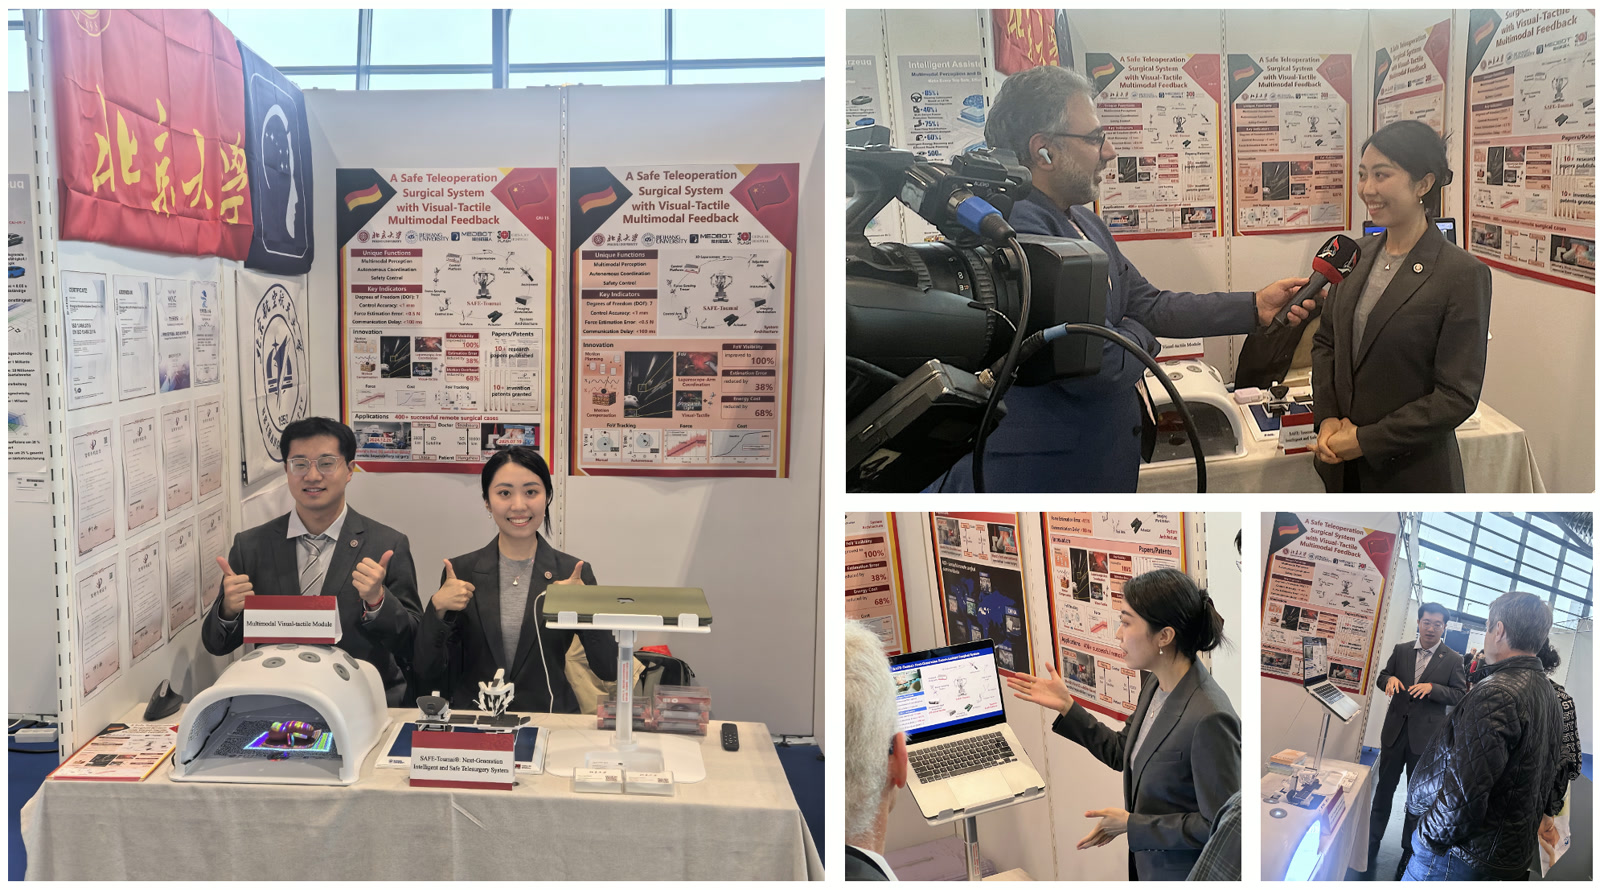
- Related prototype: SAFE-Toumai teleoperation. Visual–tactile feedback and assistive motion control.
- Force estimation from structured-light vision and robot dynamics, with reported error below 0.5 N.
- Camera–arm coordination under visibility and joint-velocity constraints.
- Hand-tremor filtering and organ-motion compensation.
Autonomous Exploration & Navigation
- Autonomous indoor exploration and navigation on a mobile robot.
- RRT-based frontier exploration.
- TARE-style hierarchical exploration.
- Mapping, path tracking with ROS 2 Navigation2, and indoor robot deployment.
Data Pipelines and VLN Evaluation
- Simulation data pipelines and vision-language navigation evaluation.
- Motion-planning trajectory collection and 3D occupancy data preparation.
- Automated outdoor scene generation and asset placement in Isaac Sim.
- Video-to-3D perception benchmarking and SPAN-Nav evaluation on MetaUrban and UrbanSim.
Fast Task Allocation & Online Replanning
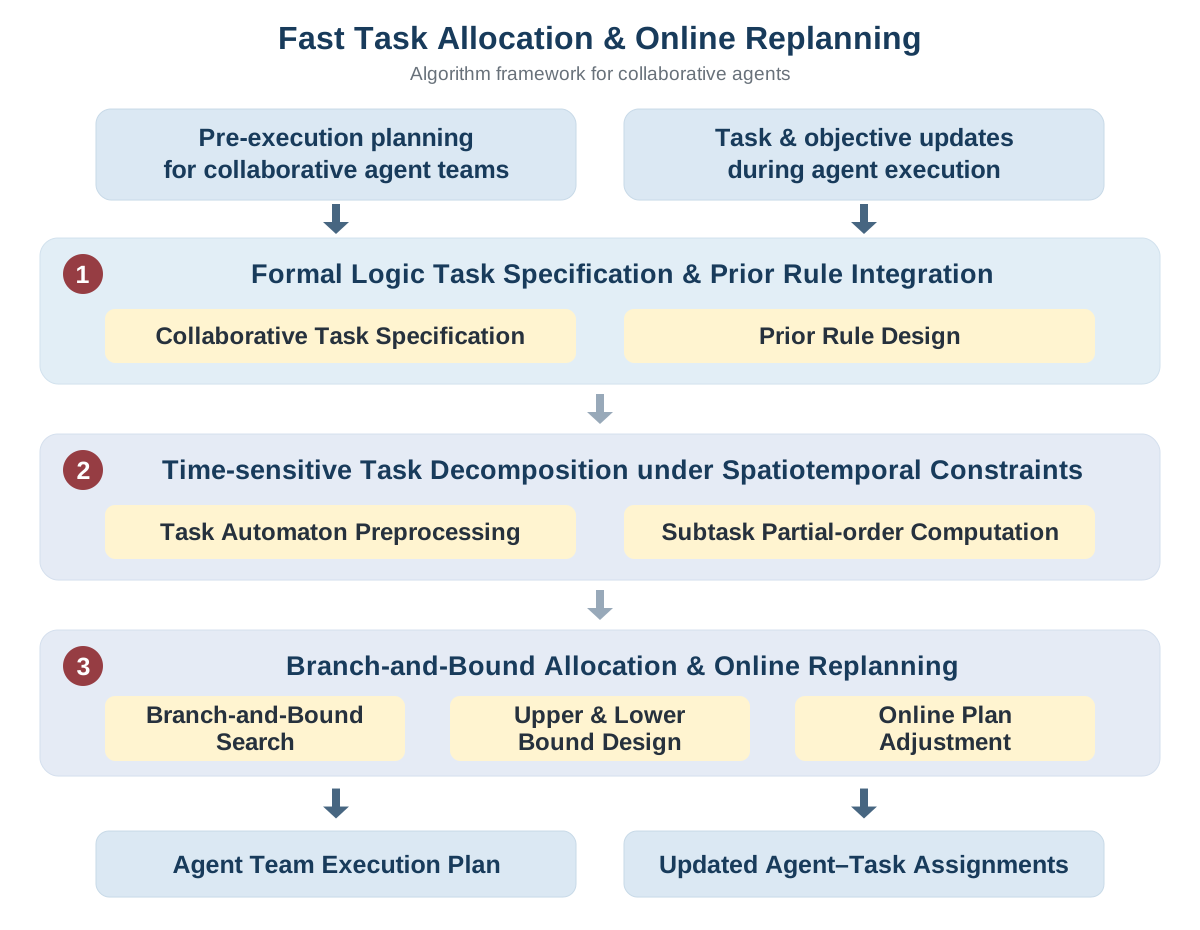
- Constraint-aware task allocation and online replanning for heterogeneous robot teams.
- LTL task modeling and partial-order decomposition for parallel execution.
- Capability, resource, and time-window constraints for synchronized multi-robot tasks.
- Anytime branch-and-bound search for feasible schedules and shorter makespans within a time budget.
- Replanning unfinished tasks after agent availability changes or task additions and cancellations.